Summer Internship (Nov 2026 – Feb 2027)

Baboo Balan

Applied AI & Robotics Engineer

I'm finishing a Master of Applied Computing at Lincoln University and looking for a summer internship in New Zealand from November 2026. I build computer vision and document-search systems. Before that I spent 8+ years commissioning robots and wafer-handling automation in Singapore, Taiwan and India, so I know how these systems behave on a real factory floor.

Baboo Balan, applied AI and robotics engineer based in Christchurch, New Zealand
LOC
Current location
Christchurch, NZ
Christchurch, Lincoln or remote
DEG
Current degree
Master of Applied Computing
Lincoln University (COMP639)
AVL
NZ availability
Nov 2026 – Feb 2027
Summer internship or COMP693 placement
VISA
NZ work rights
Student visa
Full-time in the summer break
8+
Years industrial depth
Semiconductors, robotics, AMHS
1
Granted patent
No. 439813 (co-inventor)
2024
ST STAR Award
STMicroelectronics Singapore
30%
Throughput gain
Lights-off production, STMicroelectronics
Professional Profile

Industrial automation, applied to computing and AI

Currently advancing through the Master of Applied Computing at Lincoln University, New Zealand, my core focus is applying software engineering, computer vision and machine learning to real systems for New Zealand industries.

Through Lincoln COMP639 Agile Studio and independent research, I design and ship applications: Kiwi Sorter (YOLOv8 + Detectron2 AR inspection), Rōpū Mapi (standalone Android APK with native voice navigation), SmartShop (Canterbury grocery PWA with Gemini Vision) and DocMindAI (hybrid RAG search engine).

That work sits on 8+ years of industrial engineering across Singapore, Taiwan and India: automation systems, AMHS cleanroom handling, Universal Robots and MiR AMRs at STMicroelectronics (ST STAR Award 2024 for a 30% throughput increase), Tata Electronics and Solomon Technologies.

Applied software & AI Industrial robotics

The engineering bridge

Vision models fail differently on a factory floor than in a notebook: lighting shifts, parts arrive misaligned, and a stopped line is expensive. I've spent eight years on that floor. Now I build the models too.
Core Competencies

Computer vision, software and robotics skills

Grounded in shipped repositories, unit tests and factory-floor work.

AI
AI & PERCEPTION

Applied AI & Computer Vision

Model fine-tuning, defect segmentation & RAG architectures

  • LanguagesPython, SQL, JavaScript, C#, HTML/CSS; TypeScript (Node.js relay)
  • Computer VisionYOLOv8, Detectron2 (Mask R-CNN), OpenCV, GrabCut (37 px/cm defect sizing)
  • RAG ArchitectureLangChain, FAISS dense vector store, BM25 keyword search, Reciprocal Rank Fusion (RRF)
  • Multimodal APIsClaude Vision API, Gemini Vision API
YOLOv8Detectron2PyTorchFAISSLangChain
SW
SOFTWARE & EDGE

Full-Stack & Mobile Edge

APIs, mobile APKs, databases & a GitHub Actions APK build

  • APIs & DatabasesFlask REST APIs, Gunicorn, PostgreSQL, Linux (Ubuntu)
  • Mobile & NativeCapacitor 8 (standalone Android APK), PWA, IndexedDB
  • DevOps & QADocker, Docker Compose, 85 automated unit tests (SmartShop), GitHub Actions APK build
  • Agile StudioLincoln COMP639: two Scrum sprints, 35 user stories, 46 pull requests, Jira
Capacitor 8FlaskPostgreSQLDockerAndroid SDK 35
HW
ROBOTICS & HARDWARE

Robotics & Industrial Automation

AMRs, collaborative robotics, AMHS & precision motion

  • RoboticsUniversal Robots cobots and MiR AMRs (certified service personnel)
  • Semiconductor FabAMHS (OHT, OHB, stockers), Class 5 FOUP stocker machines, lights-off automation
  • Process Engineering25% cycle-time reduction at Akribis through process redesign and tooling
  • Smart Manufacturing30% lights-off throughput increase at STMicroelectronics (ST STAR Award 2024)
MiR AMRUniversal RobotsAkribis MotionAMHS CleanroomPatent No. 439813
Selected Work

AI and robotics engineering projects

Architecture, tests and source code for each system.

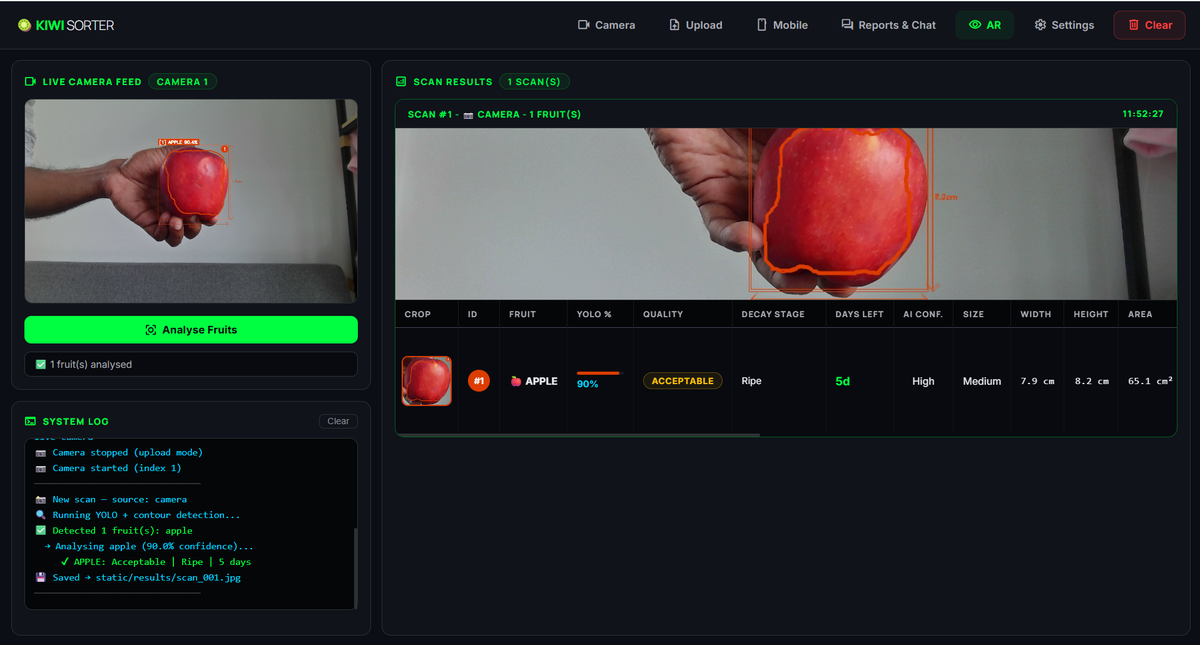
Kiwi Sorter: AI Fruit Quality & AR Inspection interface
FLAGSHIP AI/ML

Kiwi Sorter: AI Fruit Quality & AR Inspection

Computer Vision & AR

YOLOv8s detects fruit from a webcam, OpenCV GrabCut measures width, height and area in centimetres (37 px/cm), and the Claude Vision API grades each fruit across 10 fields. Bounding boxes are anchored on real fruit through XReal One AR glasses. Two Mask R-CNN models were fine-tuned separately in Detectron2.

YOLOv8Detectron2GrabCut (37 px/cm)Claude Vision +2
Rōpū Mapi: Convoy Navigation & Native Voice interface
STANDALONE ANDROID APK

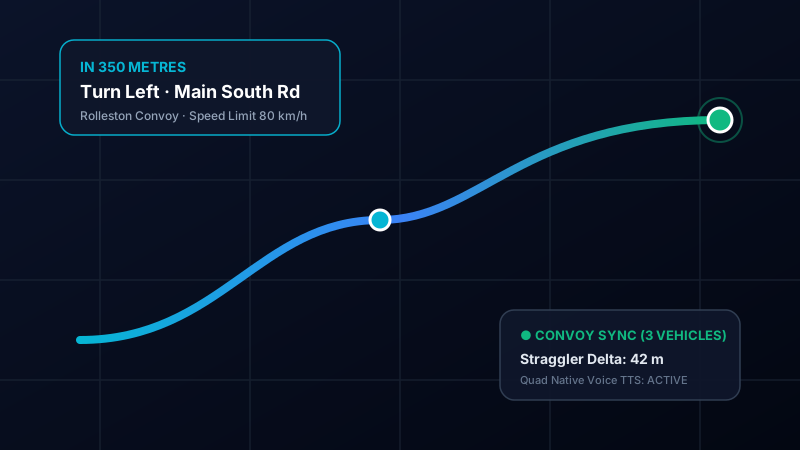
Rōpū Mapi: Convoy Navigation & Native Voice

Mobile & Embedded UI

Open-source convoy navigation app built as a standalone Android APK with a GitHub Actions workflow. Features a four-layer native TTS voice bridge, speed limit alerts, auto-rerouting, and solo navigation without a backend server (routing and map tiles still need a data connection).

Capacitor 8 (APK)Android SDK 35MapLibre GLOSRM +2
SmartShop: Retail Intelligence & Receipt Vision interface
CANTERBURY PWA

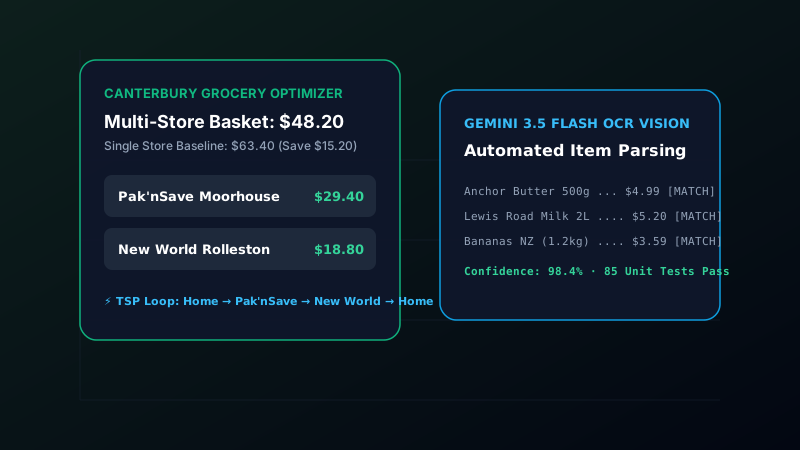
SmartShop: Retail Intelligence & Receipt Vision

Full-Stack PWA & Vision

Canterbury-tested grocery PWA with OpenStreetMap Overpass retail store discovery, Traveling Salesperson multi-store shopping route optimization, and Gemini 3.5 Flash receipt vision, backed by 85 passing unit tests.

PWAFlaskPostgreSQL 15Docker Compose +3
DocMindAI: Hybrid RAG Engine interface
HYBRID RAG

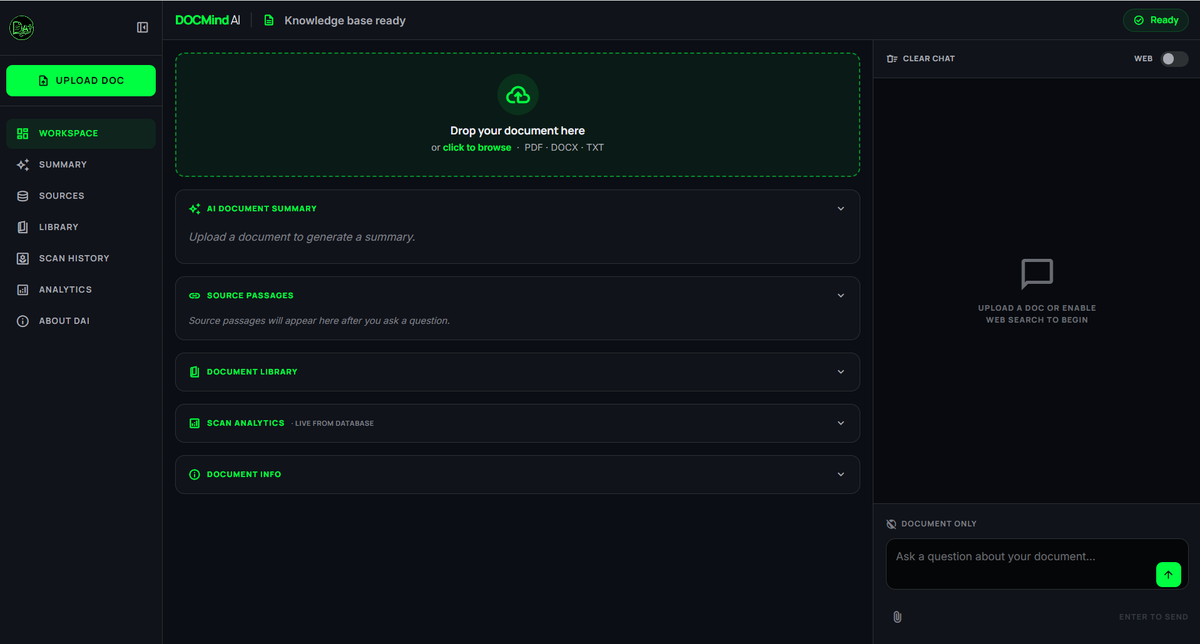
DocMindAI: Hybrid RAG Engine

LangChain & Vector Search

Document intelligence engine combining FAISS dense vector search with BM25 keyword matching via Reciprocal Rank Fusion (RRF). Features scoped document querying, inline citations, SQL analytics, and Docker deployment.

LangChainFAISSBM25 Keyword SearchReciprocal Rank Fusion (RRF) +2
Modular Cobot + AMR Mobile Platform interface
COMMERCIAL PRODUCT

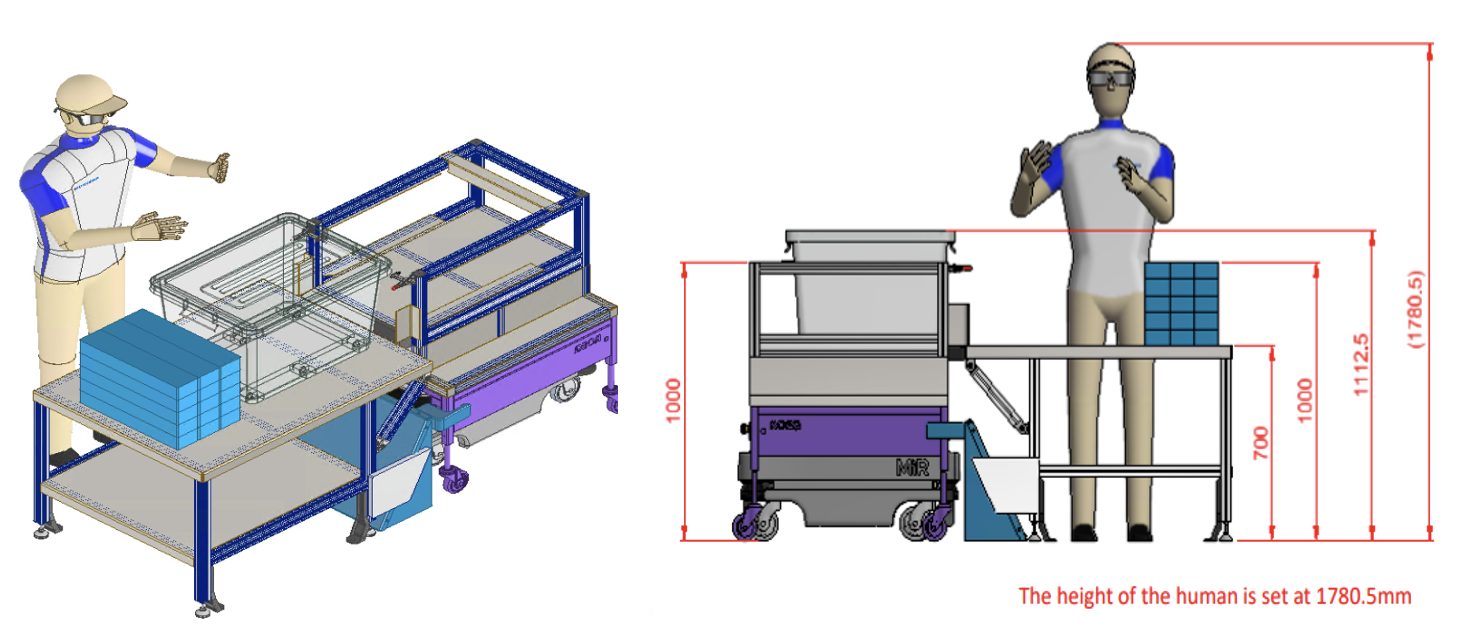
Modular Cobot + AMR Mobile Platform

Skymech Singapore

Self-designed mobile manipulator combining MiR autonomous base with Universal Robots arm. Features a ~30-minute rapid swap, a URCap interface and built-in safety interlocks. Sold and delivered 3–4 units, used for machine-to-machine transfer and aircraft-engine visual inspection at Pratt & Whitney Singapore.

MiR Mobile RobotUniversal Robots UR ArmURCap InterfaceSafety Interlocks +1
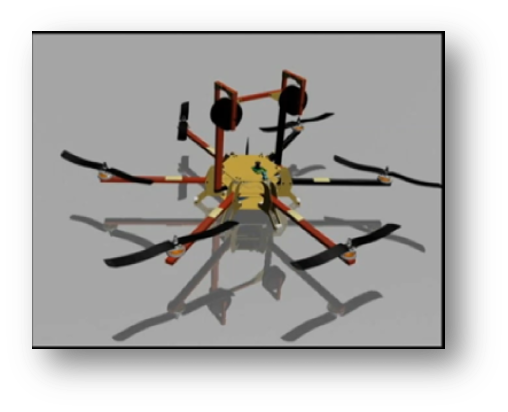
Power Line Inspection Robot (Hexarotor) interface
GRANTED PATENT NO. 439813

Power Line Inspection Robot (Hexarotor)

Co-Inventor

Teleoperated hexarotor crawler engineered to land on live high-voltage power transmission lines and traverse conductors using rubber-coated rollers. Pan-tilt camera streams wireless video for ground inspection without helicopters or climbing.

Hexarotor UAVHigh-Voltage EMI ShieldingRubber RollersWireless Video Downlink
Career Track Record

Automation engineering experience

8+ years delivering measurable engineering and fab efficiency gains.

01 / 06

Senior Industrial Engineer & AMHS Team Lead

Tata Electronics
02/2025 - 01/2026
India
  • Designed the end-to-end AMHS architecture (OHT, OHB, stockers) for a greenfield semiconductor fab, covering layout, automation flow and storage design, with throughput calculations to size the system.
  • Coordinated vendor integration across 6 international suppliers and managed project costs.
  • Acted as the bridge between the Taiwan and India teams and managed stakeholders through deployment.
02 / 06

Global Field Application Engineer, AI Vision Systems

Solomon Technologies
09/2024 - 01/2025
Taipei, Taiwan
  • Assessed each customer's part, chose the inspection tool in the AI vision software that fitted it, and validated the configuration on the customer's real product before handover.
  • Covered pre-sales, sales and after-sales support; ran AI vision demonstrations across Asia-Pacific and configured inspection systems for high-precision manufacturing lines.
03 / 06

Industrial Engineer & Automation Product Manager

STMicroelectronics
08/2022 - 07/2024
Singapore
  • Increased lights-off manufacturing throughput by 30% through automation redesign (ST STAR Award 2024).
  • Designed end-to-end automation systems: automation flow, choice of automation type, and hardware, software and control-system integration for lights-off production.
  • Oversaw and installed 15 mobile manipulators (DF Automation AGVs with Techman arms) on the shop floor.
  • Led cross-functional digital transformation initiatives and fab-wide PMO projects; self-initiated a HoloLens AR visualiser (Unity, MRTK) overlaying live machine status on the factory floor as a proof of concept.
04 / 06

Industrial Engineer & Team Lead

Akribis Systems
02/2022 - 08/2022
Singapore
  • Reduced manufacturing cycle time by 25% through precision process redesign and tooling improvements.
05 / 06

Senior Sales & Application Engineer, Robotics

Skymech Automation
03/2019 - 02/2022
Singapore
  • Originated a mobile manipulator product in 2020 (UR cobot on a MiR base): system architecture, plug-and-play redeployment (30-minute swap), centre-of-gravity and payload limits per UR model, and built-in safety (software safety wall, speed control, lidar interlock).
  • Released a unified UR and MiR control interface as a URCap with a programmer; sold and delivered 3–4 units, personally programming and deploying them for machine-to-machine material transfer and aircraft-engine visual inspection at Pratt & Whitney Singapore.
  • Full cycle on UR cobots and MiR AMRs from pre-sales to service as a UR and MiR Certified Service Personnel; delivered 50+ integration projects across Southeast Asia; met sales KPI at 110% or higher.
06 / 06

R&D Engineer

Chiff Technologies
06/2017 - 07/2018
Taiwan
  • Project engineer designing fully automated inline FOUP storage stocker machines (Class 5) for TSMC and UMC fabs.
  • Gathered customer requirements and checked feasibility with other departments to build custom ODM and OEM machines.
Academic Foundations

Education & qualifications

Master of Applied Computing at Lincoln, NCKU Taiwan, and Veltech India.

ENROLLED · IN PROGRESS

Master of Applied Computing

Lincoln University
Feb 2026 – present (completion expected mid-2027) · Christchurch, New Zealand
  • COMP639 Studio: team Flask/PostgreSQL app delivered over two Scrum sprints, 35 user stories and 46 pull requests, every change peer-reviewed and tested on the deployed instance.
  • COMP636: LEO, a multi-user Flask/PostgreSQL app deployed on PythonAnywhere. COMP640: 45-screen Balsamiq prototype with heuristic evaluation. COMP642: object-oriented Python.
  • COMP693 industry placement planned for Summer School 2026/27.
COMPLETED · ROBOTICS THESIS

MSc, Mechanical Engineering

National Cheng Kung University (NCKU)
Sep 2014 – Jun 2016 · Tainan, Taiwan
  • Thesis: "Design and Development of a Small-Scale Humanoid Robot for Human Motion Replication": 33-DOF, 40 cm humanoid.
  • Mechanical design, centre-of-gravity calculations and conversion of captured motion data into PWM servo commands, stable in every pose including one-leg poses.
GRADUATED · CAPSTONE PATENT

BE, Mechanical Engineering

Veltech Technical University
Sep 2010 – May 2014 · Chennai, India
  • Final-year project: the Live Power Line Inspection Robot, built with a team and granted as Indian Patent 439813 (filed 2014, granted 2023).
  • 1st Place, Gridtech 2013 National Robotics Competition.